LiDAR measures surfaces
Laser returns provide distance observations around the scanner. The sensor’s coverage and the visibility of a surface determine what can be sampled.
LiDAR & SLAM
LiDAR samples distances to surrounding surfaces. SLAM—simultaneous localization and mapping—estimates the scanner’s movement while building a map. Together, they support portable spatial capture through connected environments.
Measurement and mapping
Laser returns provide distance observations around the scanner. The sensor’s coverage and the visibility of a surface determine what can be sampled.
The mapping system relates observations across the capture route to estimate movement and assemble the surrounding geometry into a map.
Supported handheld scanners display coverage during collection. Use preview to identify missed areas while you can still adjust the route.
Cameras and motion sensors provide additional observations in supported systems. The sensor configuration and processing vary by product.
How it works
Identify the required spaces, access points, and likely obstructions.
Move steadily with surrounding geometry visible to the sensor.
Check preview coverage and revisit required surfaces where practical.
Inspect the assembled map and verify it against project requirements.
Field preview supports capture decisions. Project accuracy still needs evaluation using the intended processing workflow and control.
In practice
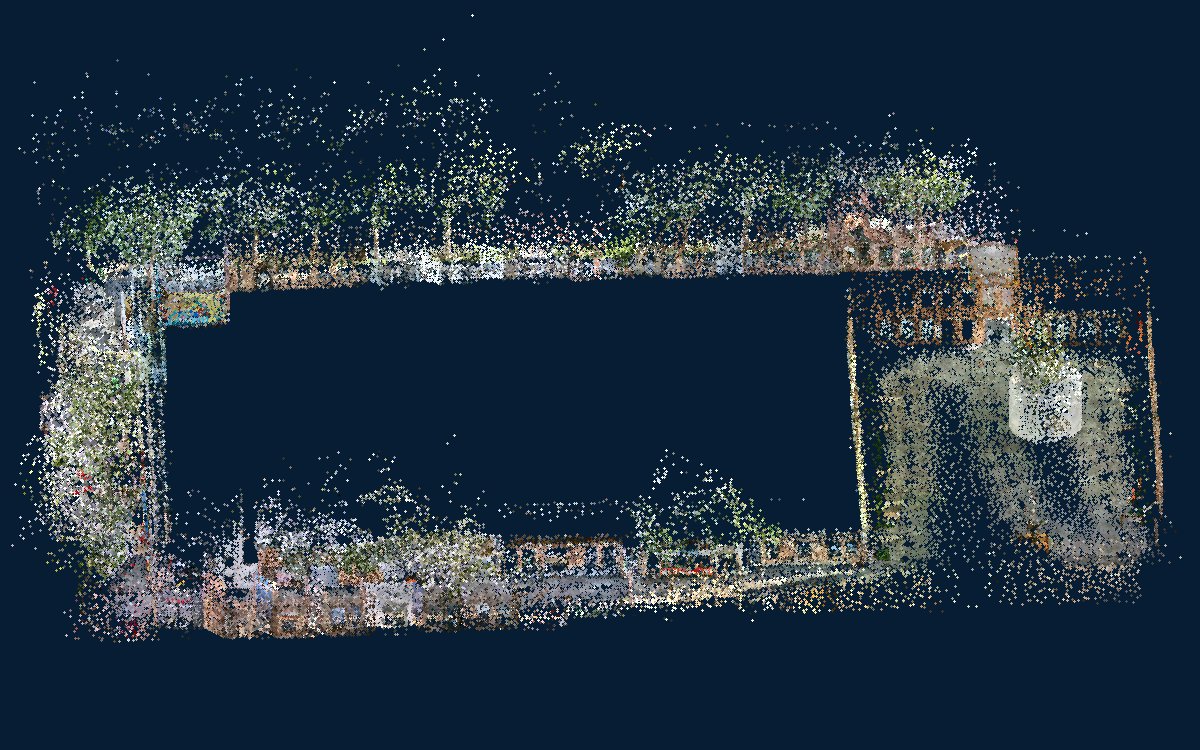
The supplied Cobra S sample shows a colorized point cloud produced from a handheld capture workflow. Use it to explore the data representation, then plan a demonstration around your own environment.
Practical evaluation
Scanner selection
Cobra, Pentra, Radix, and Staris offer different sensor configurations, fields of view, weights, and battery options. Compare those characteristics with the distances, access constraints, and output requirements on your project.
SLAM estimates movement from observations of the environment, while satellite positioning provides a different positioning input. Systems may combine these approaches where the hardware and workflow support them.
Point rate describes how many measurements are produced over time. Accuracy also depends on sensor performance, capture conditions, alignment, processing, and project control.
The recorded observations are processed into the supported spatial outputs. Explore point clouds and 3D modeling →